VECTOR drive algorithm
The vector control algorithm, also known as field-oriented control (FOC), is an advanced method of motor control for BLAC motors, with the sinusoidal back-EMF. Unlike simpler control methods, FOC precisely controls the magnetic field and torque production in the motor by manipulating the current in all motor phases simultaneously.
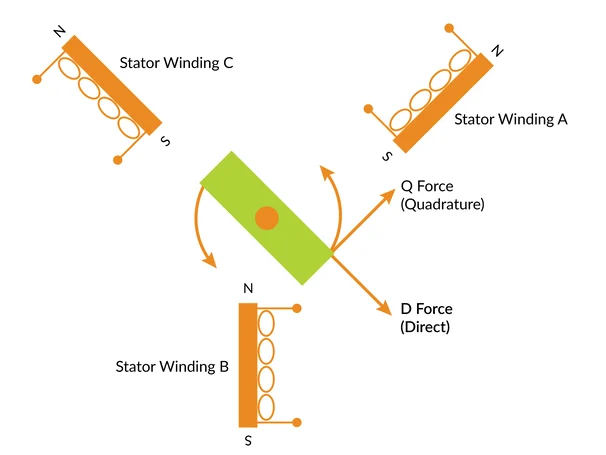
The core principle of FOC is based on transforming the motor's electrical quantities between the stationary AC reference frame (stator) and the rotating DC reference frame (rotor). This transformation allows the control system to work in a simplified DC domain, defined by two key axes:
- The quadrature axis (q-axis), which is responsible for torque generation
- The direct axis (d-axis), which is responsible for flux generation
The algorithmic coordinate transforms can be viewed as a continuous commutation (on the contrary to the six-step sequence of the BLDC drive). FOC is often considered superior to other motor control algorithms because it allows for a wide variety of control schemes, better precision, and improved efficiency across a wide range of operating conditions.
vcf [-]
The parameter is located in /driver/ folder.
Vector control algorithm flags.
| Value | Name | Description |
|---|---|---|
| 1 | Bit 0 | Favor precision of the D-axis current over the torque range and dynamic response (reworked in driver 6) |
| 2 | Bit 1 | Favor the D-axis (flux) voltage over the Q-axis voltage when the voltage limit is reached |
| 4 | Bit 2 | disable positive current control for the D-axis |
| 8 | Bit 3 | disable negative current control for the D-axis |
| 16 | Bit 4 | Voltage compensation - keep the commanded speed constant under load when dxc is set (reworked in driver 6, see the tip below) |
| 64 | Bit 6 | disable dead-time compensation (ESCx 5.0 and above) |
E.g. setting bits 2 and 3 together (the decimal value of 12) will turn off D-axis current control yielding to the frequency inverter mode.
Bit 4 is the historical voltage compensation, reworked. With dxc set, a motor in the voltage drive modes may speed up under load; with bit 4 set, the commanded speed stays constant under load. Off by default; works also with fwp = 0.
Example values
A default value is zero. Other values are considerable for these use cases:
| Value DEC | Use case |
|---|---|
| 1 | Favor precision over torque range and dynamic response. |
| 2 | IPM motor with regeneration in high field weakening. |
| 12 | Frequency inverter mode: driving an ACIM or a transformer. |
| 16 | Precision torque control/estimation with an IPM motor. |
| 64 | Silence the switching noise for a low-inductance motor. |
Adjusting this parameter requires deep knowledge of the vector drive principles. Not all combinations are meaningful and incorrect setting of these bits may result into unexpected behavior. Please contact siliXcon for further assistance.