Mode/cmd change limiters
These limiters are used to smoothen the transitions in case of step (or rapid) change of drive command. It also smooths transitions from one drive mode to another. The command filter shapes the command changes themselves.
Their activity is indicated by the CSR bit in /driver/limit word.
The following variables are located in the /driver/limiter folder.
Parameters
Sweep rate limiter
Sweep rate limiter is a special limiter that reacts to changes in the drive command or the drive mode. It aims to smoothen the transitions in case of step (or rapid) change of drive command. It also smooths transitions from one drive mode to another. If this limiter is turned off, command steps and transitions between modes could cause mechanical shocks and vibrations.
Sweep rate limiter reaction:

Influence of ccgain on limitation (ccdamp = 0,001):

ccdamp [lpf]
Command Change damping limiter. Phase current is limited during the transition when there is a change in the command. This parameter defines for how long the limiter is active. The lower the value is, the longer the limitation is (the response is slower).
ccgain [-]
Command Change damping gain. Phase current is limited during the transition if there is a change in the command. This parameter defines the starting value of the limitation percentage.
Mode change limiter
mctim [ms]
Mode change limiter. Smoothens the motor torque during a drive mode change.
- After a mode change request, current limitation is ramped up to 100% for the
mctimmilliseconds - Then, the mode is changed (e.g. current mode -> voltage mode)
- Then, current limitation is ramped back down to 0% (limitation released) for the
mctimmilliseconds

mcflags [-]
Reserved for future use.
Command filter
The command filter smooths the drive command and the multipliers set by the application (cmd, iqmult, uqmult, iqmultr in /driver) before they reach the motor control. It acts on changes within a drive mode only: when the drive mode changes, the new command set is applied at once and the transition is smoothed by the mode change limiter (mctim).
Every value is shaped separately in two directions:
- up - the magnitude grows (more command, a multiplier being released)
- down - the magnitude falls toward zero (command released, a multiplier being applied); a change of sign counts as down until zero is crossed
clpf [up, down]
Array of two values, one per direction. The filter is updated once per millisecond.
| Value | Behaviour |
|---|---|
1 | No filtering in this direction (immediate change) |
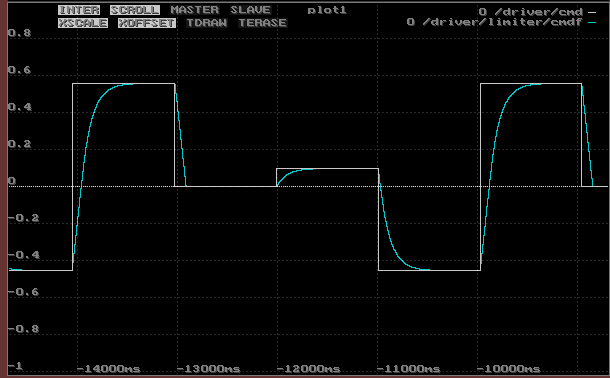
0 < value < 1 | Low-pass filter; the value is the filter gain per update, so 0.01 gives a time constant of about 100 ms |
| negative | Linear ramp; the absolute value is the maximum change per millisecond, so -0.005 takes the command from zero to full in 200 ms |
0 | Freezes the value - do not use |
Example with clpf = 0.01, -0.005 - low-pass filter on the way up, linear ramp on the way down (/driver/cmd white, /driver/limiter/cmdf cyan):
The command filter is available in the ECHO and OPHION applications. Applications with their own throttle processing (e.g. LYNX) filter the command in the CSC block of the throttle path instead (lpf, lpfdn).
States
The command set as passed on to the motor control, i.e. after the mode change limiter and the command filter.
| State | Unit | Description |
|---|---|---|
cmdf | - | Drive command |
imultf | - | Q-axis current multiplier |
umultf | - | Q-axis voltage multiplier |
rmultf | - | Q-axis brake current multiplier |